Leixin Chang
I'm a fourth-year Ph.D. student at Zhejiang University, advised by Prof. Hua Chen and Prof. Liangjing Yang. I'm currently a visiting Ph.D. student at UC Berkeley, working with Prof. Shankar Sastry. Previously, I was a robotics research intern at NVIDIA, where I worked with Duomin Wang and Lu Shi.
I'm a robotics researcher interested in legged locomotion and loco-manipulation. My current research focuses on priors guided reinforcement learning for dexterous whole-body locomotion and loco-manipulation.
leixinchang@berkeley.edu
leixin.23@intl.zju.edu.cn
Scholar X Github
2026
I joined Ember Lab at UC Berkeley as a visiting Ph.D. student, working with Prof. Shankar Sastry.2026
I joined NVIDIA as a robotics research intern.2026
Paper accepted at IROS 2026: ColoACT: Multimodal Action Chunking for Smooth Autonomous Colon Navigation on a Helical-Gear-Based Endoscopic Robot2026
Paper accepted at RA-L 2026: Where-to-Learn: Analytical Policy Gradient Directed Exploration for On-Policy Robotic Reinforcement Learning2025
Paper accepted at ICRA 2025: Beyond Robustness – Learning Unknown Dynamic Load Adaptation for Quadruped Locomotion2025
I've joined the Physical Intelligence Lab as a Ph.D. student.2025
Best Presentation Award — 1st ZJU AI+Robotics Ph.D. Forum2024
Oral Presentation at IEEE/ASME AIM 2024: Convex Optimization Based Mobile Robot Planner for Crowd Navigation2023
Best Paper Award at ICRAE 2023: Dynamic 3D Reconstruction using Moving Depth CameraWhole-Body UMI: Transferring UMI Manipulation Skills to Humanoid Whole-Body Manipulation via Real-Time Motion Generation
Yuxuan Nai, Leixin Chang, Liangjing Yang, Shuo Yang, Zhongyu Li.
Under review, 2026
Paper
Page
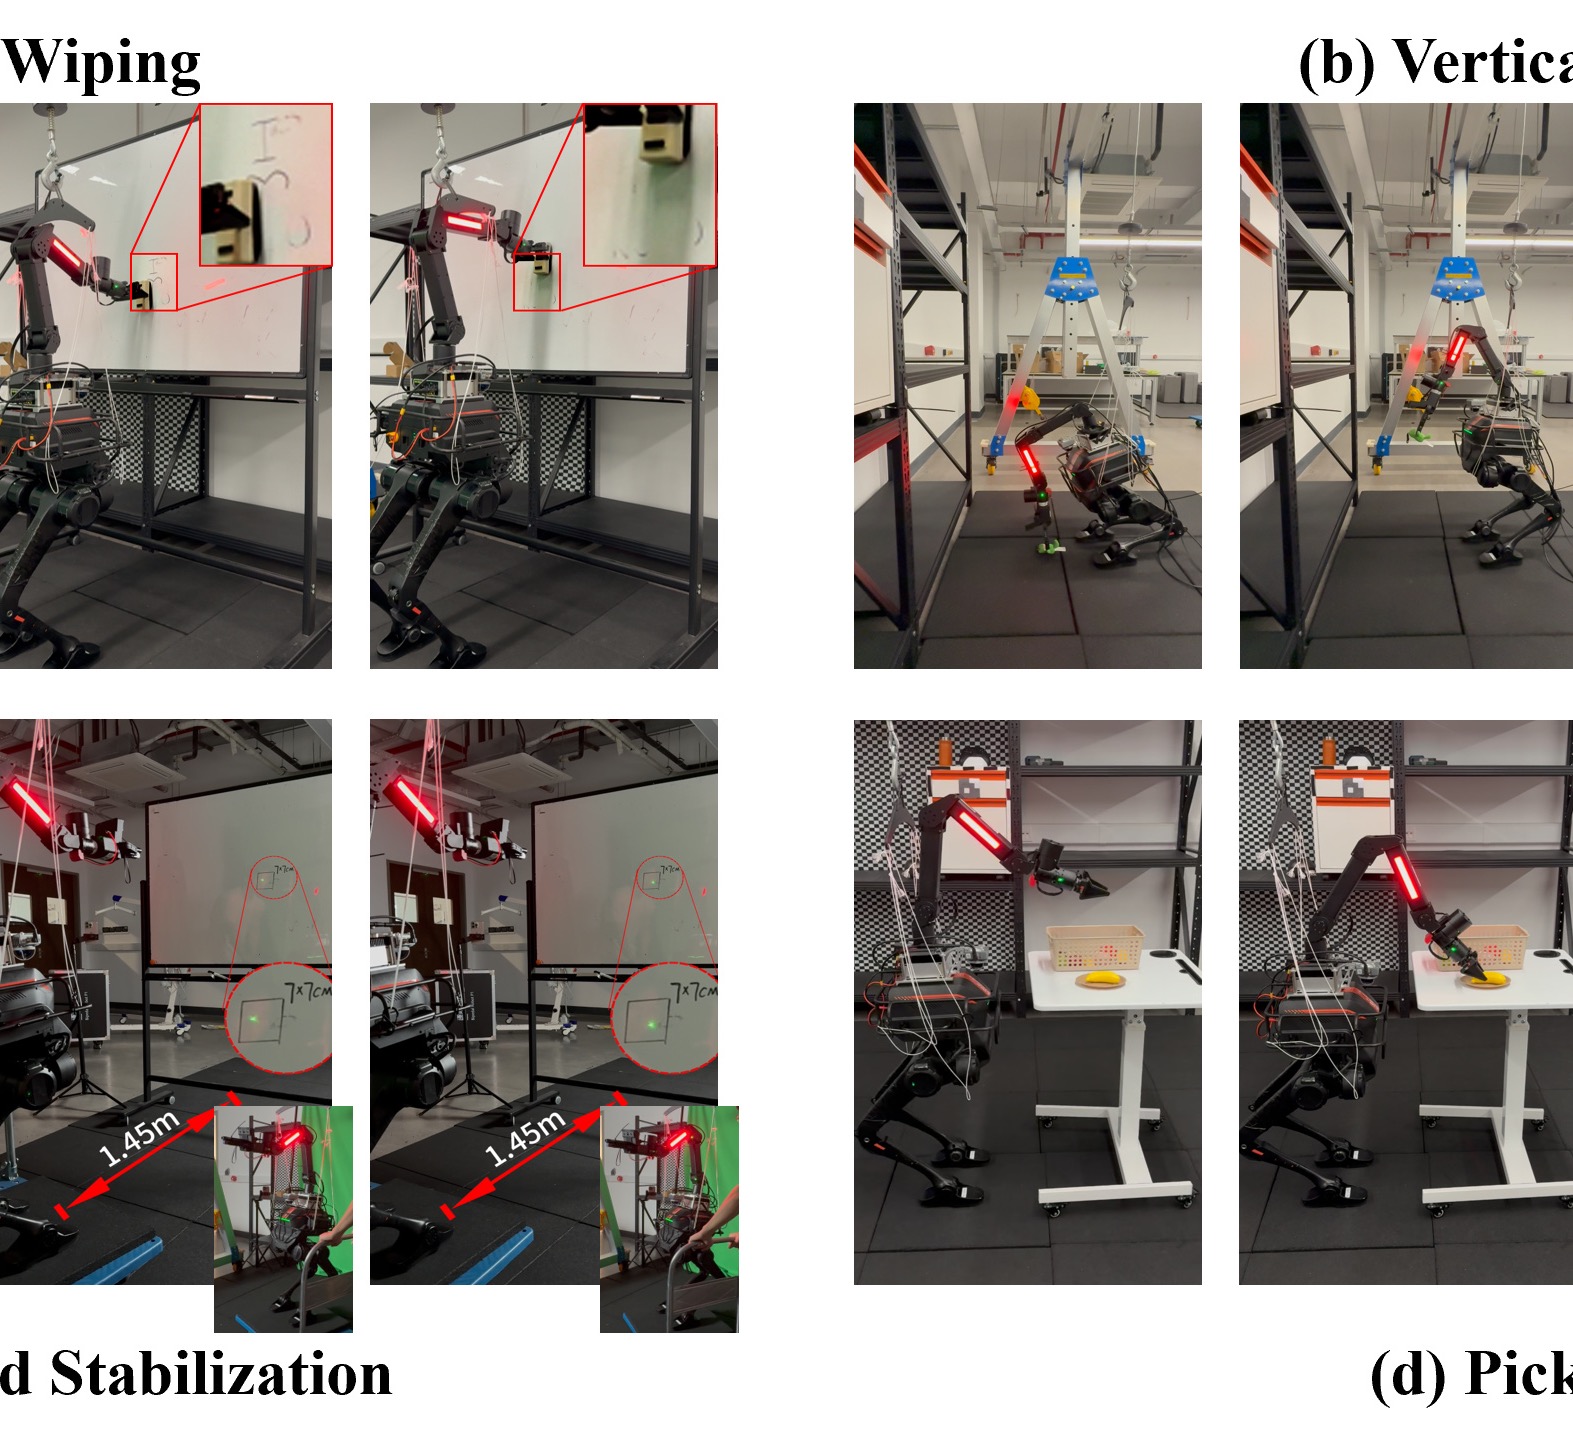
Learning Holistic Whole-Body Loco-Manipulation with a Bipedal Mobile Manipulator
Zhongyu Chen, Yuxuan Nai, Qian Chen, Yidong Zhu, Chen Jing, Qihan Wang, Xudong Li, Zhizhan Li,
Leixin Chang, Liangjing Yang, Hua Chen.
Under review, 2026
Paper
Page
Code
Video
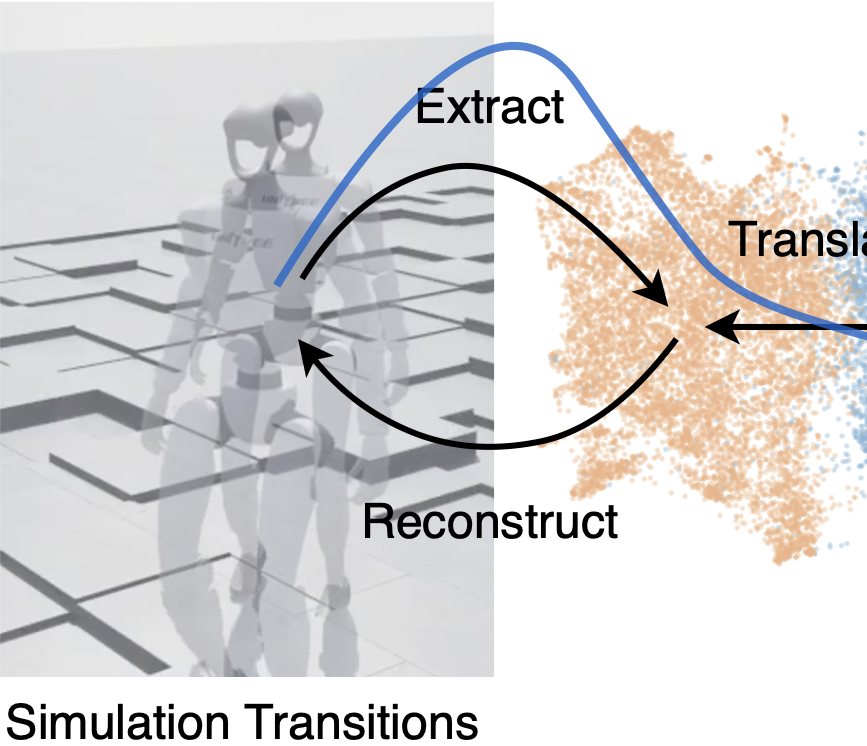
World Translation: Minimizing Sim-to-Real Gap with Backward Dynamics Extraction and Unpaired Domain Translation
Xinchen Yao, Leixin Chang, Hua Chen.
Under review, 2026
Paper
Page
ColoACT: Multimodal Action Chunking for Smooth Autonomous Colon Navigation on a Helical-Gear-Based Endoscopic Robot
Jian Hu, Shujing He, Leixin Chang, Zongze Li, Ding Huang, Chaoyang Shi, and Chengzhi Hu.
IEEE/RSJ International Conference on Intelligent Robots and Systems (IROS) 2026, Accepted
Page
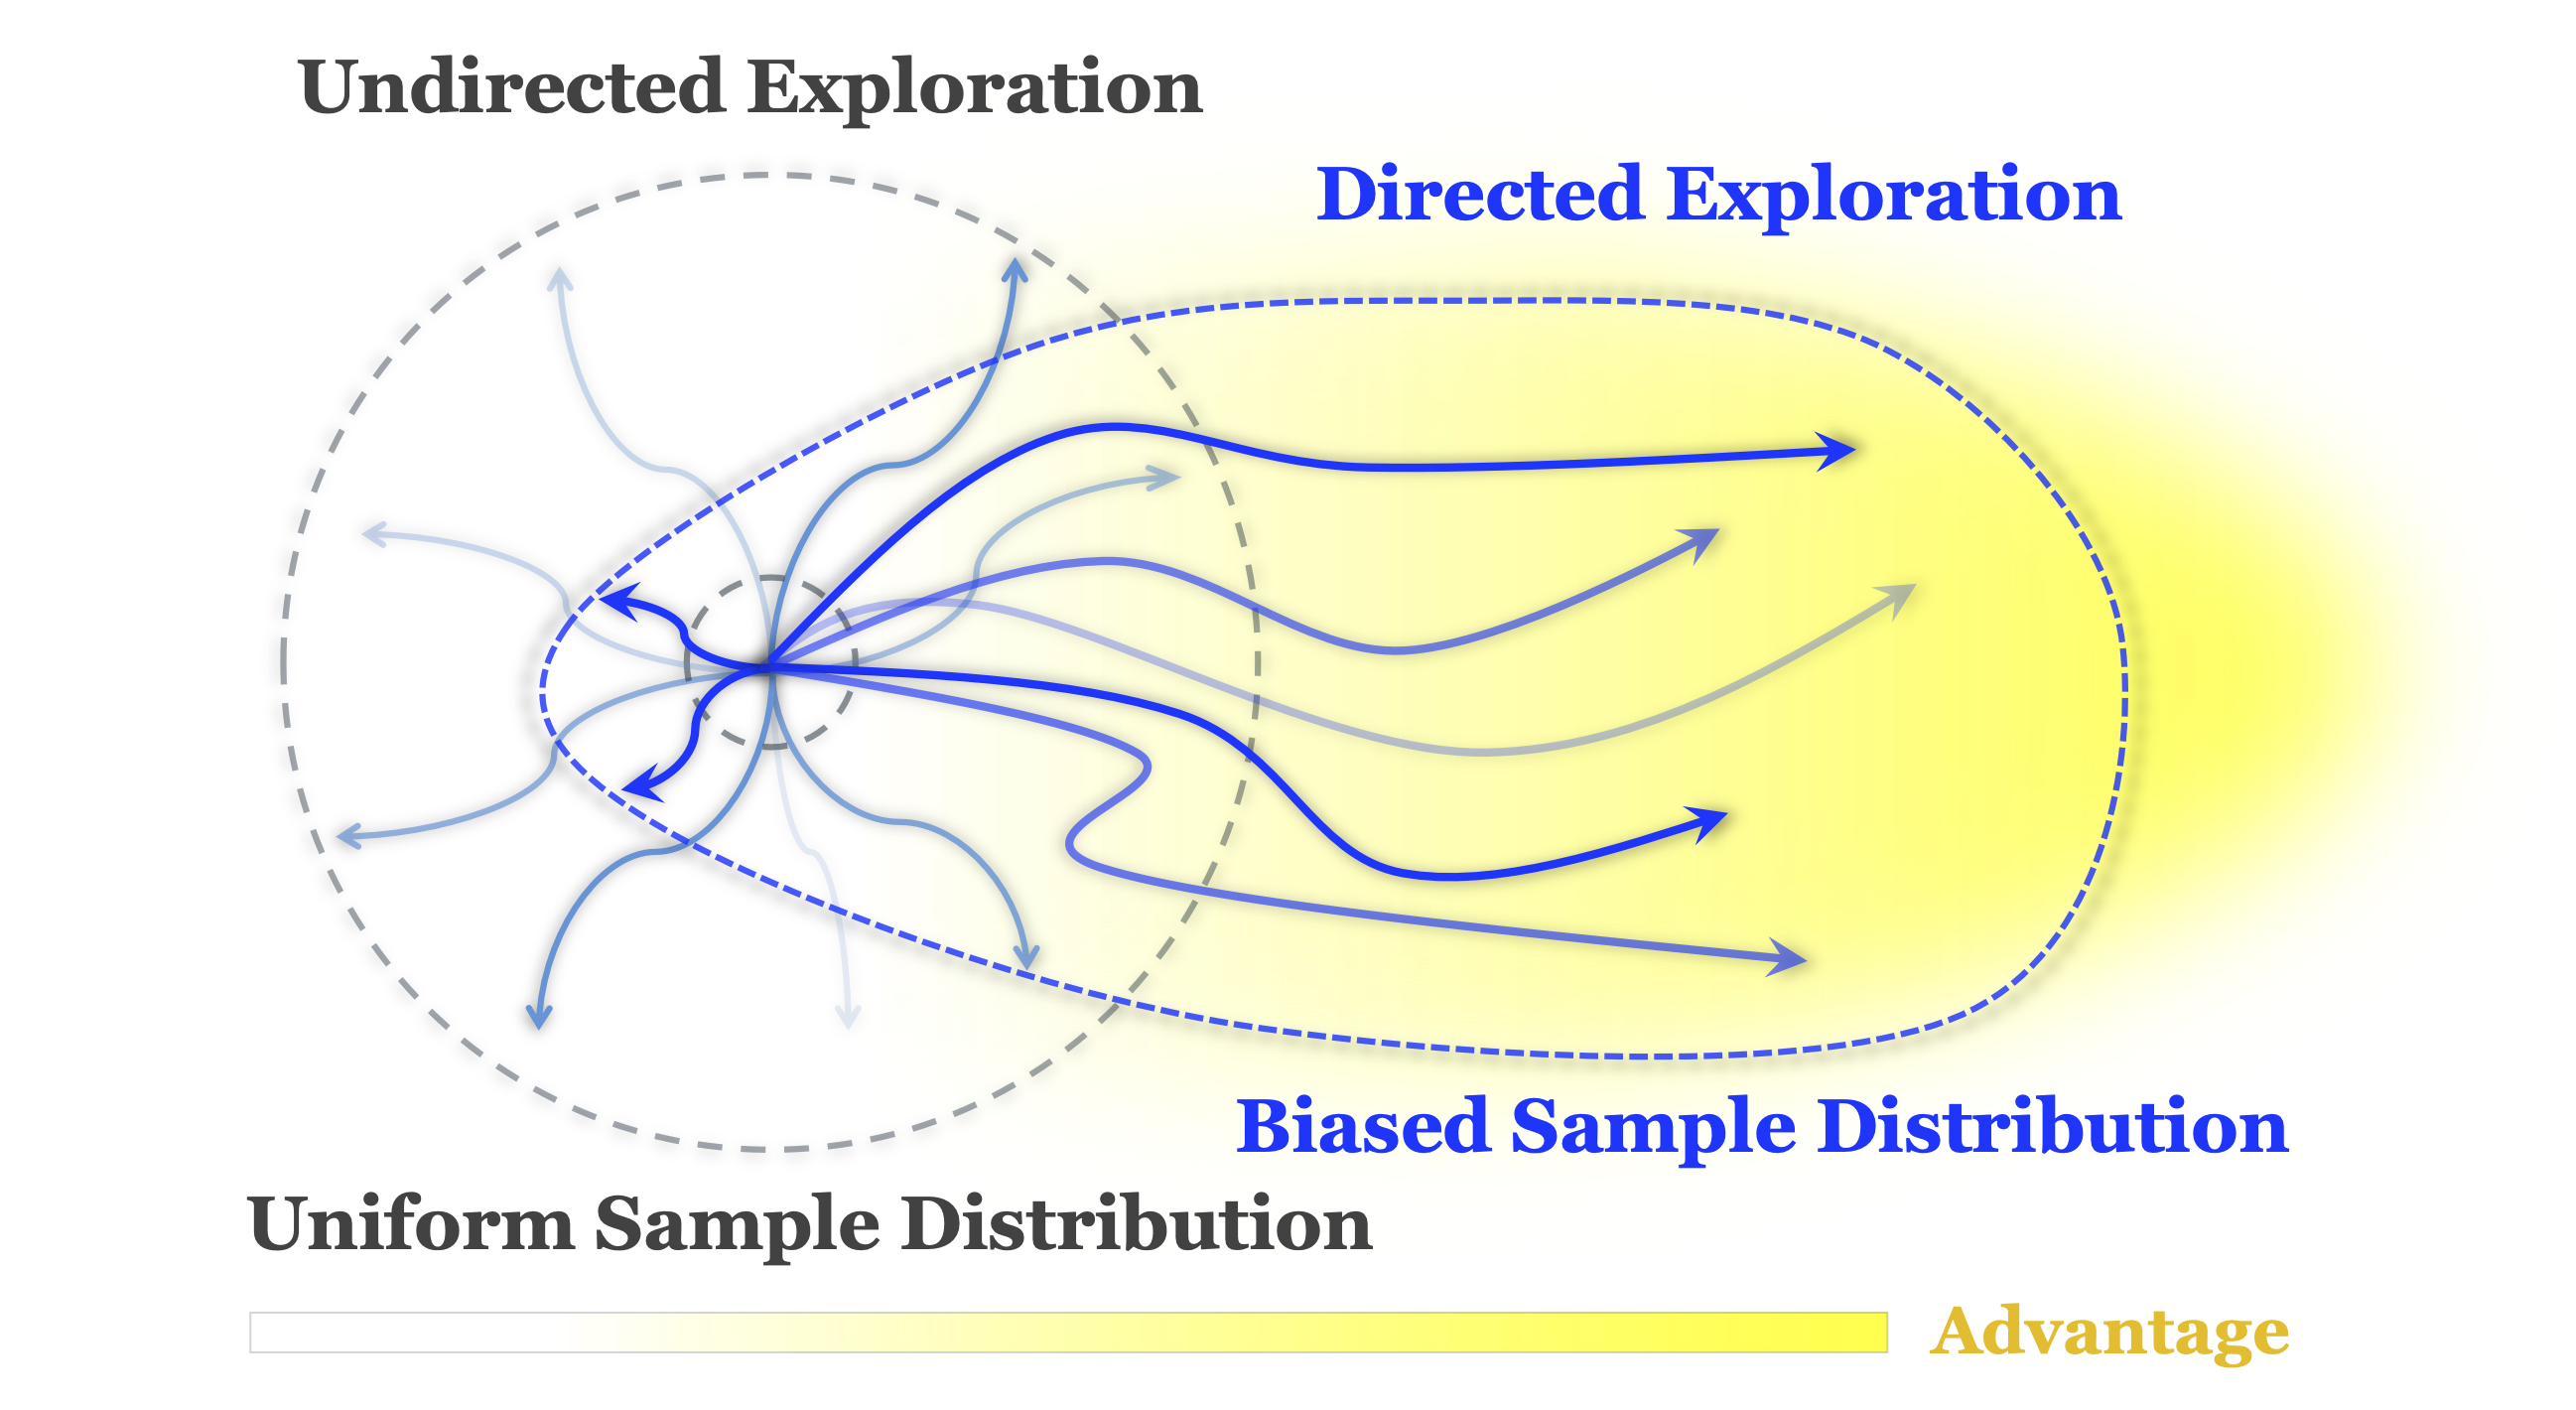
Where-to-Learn: Analytical Policy Gradient Directed Exploration for On-Policy Robotic Reinforcement Learning
Leixin Chang, Xinchen Yao, Ben Liu, Liangjing Yang, Hua Chen.
IEEE Robotics and Automation Letters (RA-L), 2026
Paper
Page
Beyond Robustness: Learning Unknown Dynamic Load Adaptation for Quadruped Locomotion on Rough Terrain
Leixin Chang, Yuxuan Nai, Hua Chen, Liangjing Yang.
International Conference on Robotics and Automation (ICRA) 2025
Paper
Page
A Convex Optimization Based Differentially Driven Mobile Robot Planner for Crowd Navigation
Leixin Chang, Haoran Yuan, Tengyue Wang, Haonan Mai, Liangjing Yang.
IEEE/ASME International Conference on Advanced Intelligent Mechatronics (AIM) 2024
Paper
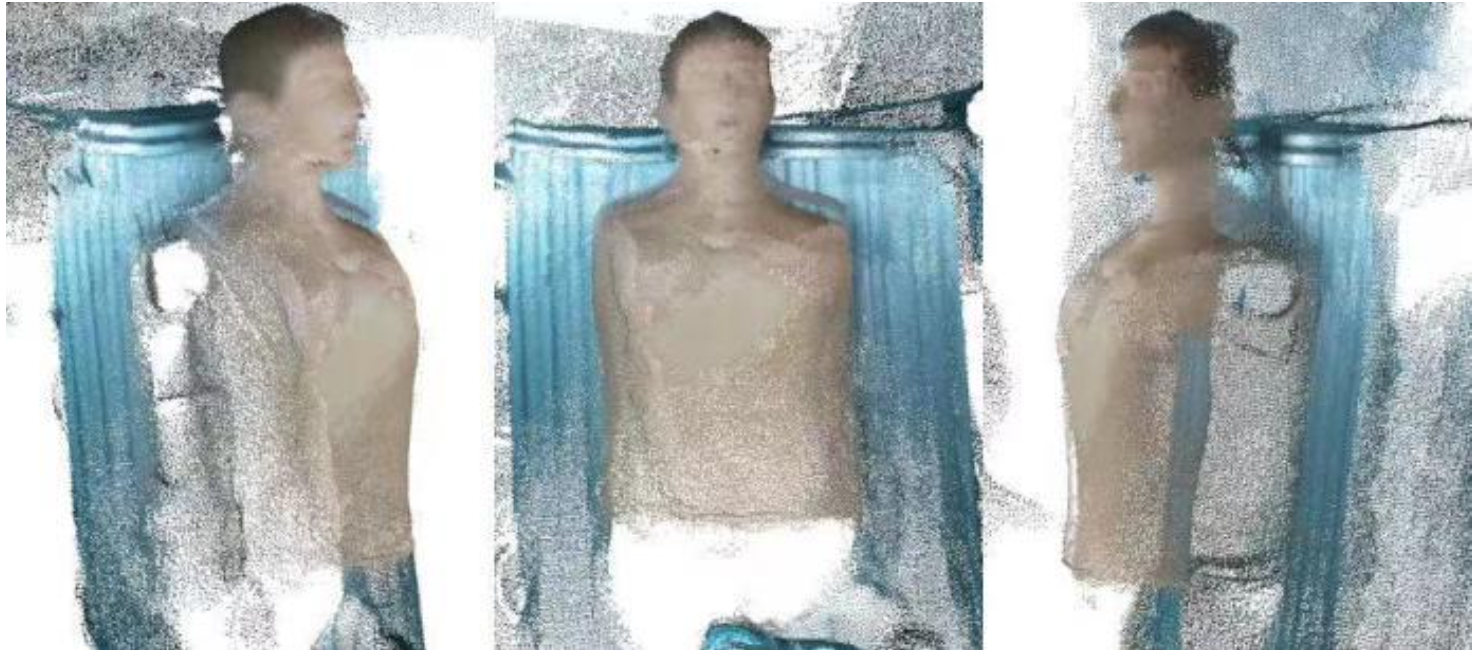
Dynamic 3D Reconstruction using Moving Depth Camera Mounted on Robotic Arm
Haonan Mai, Xianhao Chen, Leixin Chang, Liangjing Yang.
International Conference on Robotics, Automation and Education (ICRAE) 2023
Paper
★ Best Paper Award ★
Talks
2026
Reinforcement Learning for Legged Control: Robust Locomotion and Efficient LearningCAD&CG Lab, Zhejiang University, Invited by Prof. Changqing Zou
Awards
2025
Best Presentation Award — 1st ZJU AI+Robotics Ph.D. Forum, Huzhou Institute of ZJU2024
Excellent Master Student — Zhejiang University2023
Outstanding Graduate Student — Guangdong University of Technology2023
Outstanding Senior Design Award — Guangdong University of Technology